A Compact DC Motor is a small electromechanical device that converts direct current into controlled rotational motion. It appears in camera lenses, cooling fans, medical instruments, robotic joints, toys, and portable equipment. Despite its modest size, it can deliver precise movement when properly selected and controlled.
Its operation begins when current enters the motor’s windings. The windings create a magnetic field around the rotor. This field interacts with permanent magnets or a stator field, producing torque. In brushed designs, a commutator repeatedly changes the current direction as the rotor turns. Brushless designs use electronic switching instead. That difference affects noise, service life, efficiency, and control complexity. Small details matter.
From a technician’s viewpoint, motor performance depends on more than voltage. Load torque, starting current, heat, gear friction, and operating duty can change real results. A motor that spins smoothly without a load may stall inside a compact mechanism. That mistake is common. Engineers usually compare rated speed, continuous torque, peak torque, efficiency, and mounting dimensions before choosing a model. Measurement under the actual load remains more trustworthy than a catalog value alone.
This guide explains the internal parts of a Compact DC Motor and follows the energy path from electrical input to mechanical output. It also examines brushed and brushless designs, speed control, common failure signs, and practical selection factors. Some examples simplify real motor behavior, because temperature and manufacturing tolerances complicate the picture. Still, these basics provide a dependable starting point for understanding how compact motors work in everyday machines.
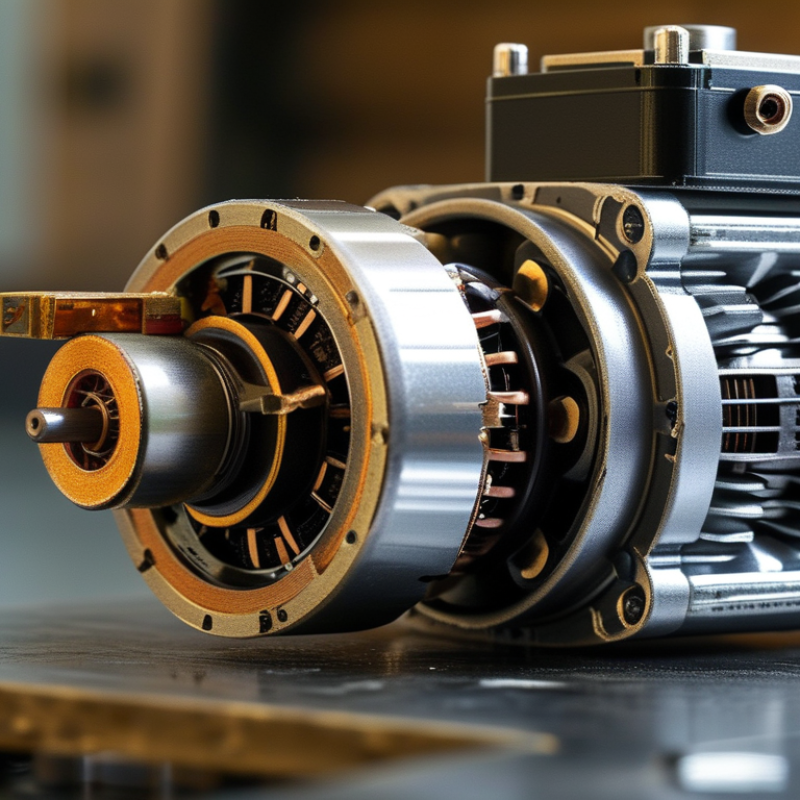
A compact DC motor is a small electromechanical device that converts direct-current electricity into rotary motion. It usually contains a stator, rotor, magnets, windings, bearings, and a commutation system. In brushed designs, carbon brushes switch current mechanically. Brushless designs use electronic controls instead. Current creates a magnetic field, and opposing magnetic forces turn the rotor. The shaft then drives a fan, pump, valve, or small actuator.
Its defining feature is a smaller physical envelope, not simply lower power. Compact motors often operate from low-voltage supplies and provide quick speed response. Designers also value high torque relative to size, simple speed control, and easy integration into portable equipment.
Heat remains a serious limitation. A crowded housing can trap warmth around the windings. The International Energy Agency estimates that electric motors consume about 45% of global electricity, making efficiency important even in small systems. The U.S. Department of Energy’s 2022 Motor Systems Market Assessment also reports that motor-driven systems use roughly 69% of industrial electricity in the United States.
Real performance depends on load, duty cycle, friction, and controller quality. A motor rated for 12 volts may still overheat under continuous stall conditions. That detail is often overlooked. Compact construction can reduce weight, but it may also reduce cooling space and serviceability. In practice, engineers should check starting torque, operating temperature, noise, shaft load, and efficiency across the full working range. A smaller motor is not automatically the better motor.
A compact DC motor converts electrical energy into controlled mechanical rotation. Its small housing often contains a permanent-magnet stator, an armature, a commutator, carbon brushes, bearings, and a central shaft. Each part has a specific job. The stator creates a fixed magnetic field around the armature. The armature carries wire coils and rotates when current flows through them. Magnetic attraction and repulsion produce torque.
The commutator reverses current direction as the armature turns. This keeps the torque moving in one direction. Brushes transfer electricity from stationary terminals to the rotating commutator. They must maintain steady contact, but they gradually wear down. The shaft delivers rotation to a fan, pump, gear train, or positioning mechanism. Bearings support the shaft and reduce friction, while the housing protects internal parts and helps control vibration. In practical testing, a motor may sound smooth but still run inefficiently. Heat often reveals the problem.
Tips: Match the motor voltage to the power supply. Check the starting current, not only the rated current. Keep the shaft load aligned. Misalignment can increase noise and bearing wear. If speed control is required, adjust voltage carefully or use suitable electronic control. A motor that spins freely without a load may behave differently under real operating conditions. That detail is easy to miss.
What Is a Compact DC Motor and How Does It Work?
How Electrical Energy Produces Rotary Motion
A compact DC motor converts electrical energy into rotary motion through controlled magnetic forces. Current enters the armature windings and creates a temporary magnetic field. Permanent magnets or field coils then attract and repel the armature. This changing force produces torque on the shaft. A commutator reverses current direction at the correct position. Rotation continues while electrical power remains available. According to the International Energy Agency’s Energy Efficiency 2023 report, motor-driven systems consume nearly half of global electricity. Even small motors matter.
In practical testing, voltage alone does not predict motor performance. Load, temperature, friction, and winding resistance also change the result. Pulse-width modulation can adjust average voltage and speed efficiently. However, switching losses and electromagnetic noise may increase. The U.S. Department of Energy reports that motor systems use about 70% of industrial electricity in the United States. This makes compact motor design more than a size challenge. It becomes an efficiency decision. A smaller housing can save space, but it may dissipate heat poorly. That trade-off is easy to underestimate.
Tips: Measure current under the real load, not only at no-load speed. Check temperature near the winding and bearings. Use a flyback diode with inductive switching circuits. Leave safety margins; laboratory results rarely match field conditions perfectly.
Compact DC motors convert electrical energy into rotary motion through magnetic interaction. A brushed motor uses permanent magnets, a wound rotor, and carbon brushes. The brushes switch current mechanically as the rotor turns. This design is affordable and easy to control, but brush wear creates dust, noise, and maintenance needs. Small, but not simple.
A brushless DC motor replaces brushes with electronic switching. Its controller energizes the windings in sequence, usually according to Hall sensors or back-electromotive-force signals. Brushless motors often provide longer service life, lower electrical noise, and better efficiency. However, their controllers increase system cost and setup complexity. Coreless motors use a lightweight rotor without an iron core, allowing quick acceleration and low inertia. Gearmotors combine a motor with reduction gears, trading speed for higher torque.
Control methods depend on the application. Basic speed control adjusts voltage, but the motor may slow noticeably under load. Pulse-width modulation offers finer control by switching power rapidly while changing the duty cycle. An H-bridge can reverse rotation and support braking. For accurate positioning, a sensor and closed-loop controller compare actual speed or angle with the target. Current limiting protects the windings during startup or overload. It matters.
In testing, I have found that a smooth PWM signal does not guarantee quiet operation. Switching frequency, load, wiring, and mechanical alignment all affect results. A feedback system is usually more reliable, although it adds tuning work. Engineers should check torque, stall current, heat, noise, and available space before selecting a motor type.
Pulse-width modulation (PWM) controls a compact DC motor by switching the supply voltage rapidly. With a 12 V supply, the ideal average voltage is approximately proportional to the duty cycle: average voltage = supply voltage × duty cycle. Lower duty cycles generally reduce motor speed, while higher duty cycles provide more torque and speed, subject to load, friction, motor characteristics, and driver limits.
Brushed DC motors are commonly controlled with voltage adjustment or PWM. Geared DC motors use the same electrical control while trading speed for higher output torque. Coreless motors respond quickly because of their low rotor inertia, whereas brushless DC motors require electronic commutation and a dedicated controller.
A compact DC motor changes electrical energy into rotary motion inside a small housing. Current creates a magnetic field, which produces torque at the shaft. In brushed designs, a commutator switches current mechanically. Brushless designs use electronic switching instead. Speed usually responds to voltage or pulse-width control, while torque rises with current demand.
Common applications include cooling fans, small pumps, valves, toys, camera mechanisms, office equipment, and battery-powered tools. Each use creates different requirements. A fan may need quiet, continuous operation. A pump may need strong starting torque and resistance to moisture. An actuator may require a gearbox, position feedback, and controlled stopping. Space also matters. A motor that fits physically may still overheat inside a tight enclosure.
Selection should begin with the load, not the motor’s advertised speed. Check operating voltage, continuous torque, starting torque, speed range, duty cycle, and stall current. Then review shaft size, mounting points, noise, vibration, temperature, and expected service life. A gearbox can increase torque, but it also adds backlash and friction. Brushed motors are often simple and economical, while brushless types may offer longer life and quieter operation. The perfect choice rarely exists. I would rather accept slightly lower speed than risk repeated thermal shutdowns. One overlooked detail is wiring: thin conductors can cause voltage loss during startup. Test the motor under its real load, because bench results can be misleading.
: Electrical current creates a magnetic field inside the armature windings. This produces torque. Magnetic attraction and repulsion turn the shaft. A commutator reverses current at the correct position. Rotation continues while power remains available.
Speed usually responds to voltage or pulse-width control. Higher voltage can increase speed, but load and heat also matter. Pulse-width control adjusts average voltage efficiently. Switching losses and electrical noise may increase.
No. Load, temperature, friction, and winding resistance affect actual results. A motor may spin quickly without a load, then slow sharply under resistance. No-load testing can create false confidence.
Measure current under the real load. Check temperature near the windings and bearings. Observe startup behavior, running speed, noise, and vibration. Laboratory results rarely match field conditions perfectly.
Begin with the load, not the advertised speed. Check voltage, continuous torque, starting torque, speed range, and duty cycle. Also review stall current, shaft size, mounting points, and service life. The perfect choice rarely exists.
A gearbox can increase shaft torque and reduce output speed. It may help an actuator or small pump start reliably. However, it adds backlash, friction, weight, and possible noise. More torque is not free.
Brushed motors use a mechanical commutator and are often simple and economical. Brushless motors use electronic switching and may provide longer service life. They can also operate more quietly. Control electronics add complexity.
Yes. A compact housing may save space but dissipate heat poorly. Continuous operation, high current, and restricted airflow raise temperature. A motor that fits physically may still fail thermally. I would accept slightly lower speed rather than repeated shutdowns.
Thin conductors can cause voltage loss during startup. Use suitable wire sizes for current and distance. A flyback diode helps protect switching circuits with inductive loads. Leave safety margins. Small details matter.
A Compact DC Motor is a small electromechanical device that converts direct-current electrical energy into rotary motion. Its compact size, efficient operation, quick response, and relatively simple structure make it useful where space and controlled movement are important. The main components typically include a stator that creates a magnetic field, a rotor or armature that turns, a commutator and brushes that switch current direction in brushed designs, and a shaft that transfers mechanical power to an external mechanism.
When current flows through the motor windings, interaction between magnetic fields produces torque, causing the rotor to spin. Compact DC motors may be brushed or brushless, and they can be controlled by adjusting voltage, current, polarity, or pulse-width modulation. Common applications include small fans, pumps, toys, office equipment, instruments, and automated mechanisms. When selecting one, users should consider voltage, speed, torque, efficiency, operating noise, size, duty cycle, control requirements, and expected service life.
WICCA Motor